Knowby Customer Demo - Test
Knowby
PRO SOS2 Palletisation Gripper Set Up 2
1
Step 1 of 5
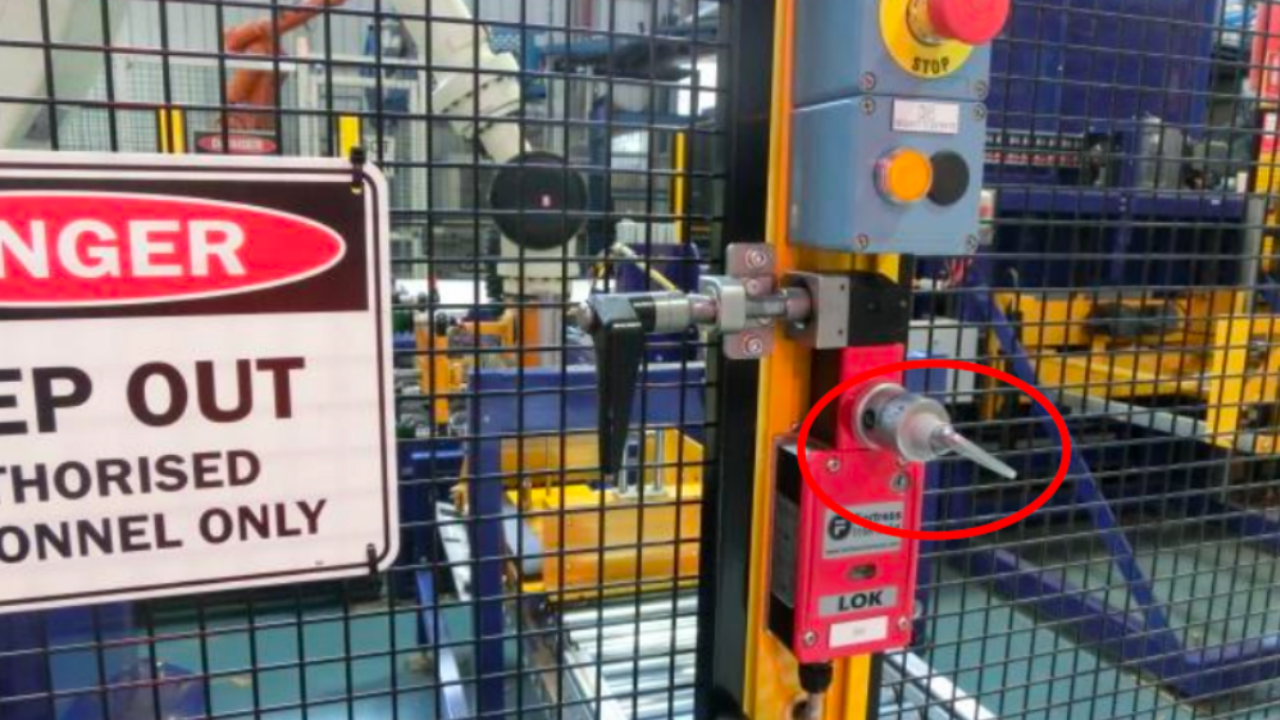
<p>Enter the robot cell using the safety access key.</p><p>This key must be in possession at all times when in the robot cell.</p><blockquote style="background-color: var(--k-quote-bg-warning);"><p>⚠️ <strong>Important:</strong> Do not leave the key in the lock or share it with others while inside.</p></blockquote><p></p>

Enter the robot cell using the safety access key.

This key must be in possession at all times when in the robot cell.

⚠️ Important: Do not leave the key in the lock or share it with others while inside.

2
Step 2 of 5
Select the correct bag
template for the finished
length of bag on the
BPO.
Select the correct bag template for the finished length of bag on the BPO.
3
Step 3 of 5
Using the correct template, place studs in locating holes of backing plate and fit nuts so that the template is secure.
4
Step 4 of 5
<p>Fully extend the right side stop cylinder and loosen the clamps to adjust the cylinder to meet the template. Tighten the locks once in correct position.</p>

Fully extend the right side stop cylinder and loosen the clamps to adjust the cylinder to meet the template. Tighten the locks once in correct position.

5
Step 5 of 5
Extend the left cylinder
down; loosen the clamp
to adjust the cylinder to
meet the template. Tighten the clamp once in correct
position.
Remove the template, so
robot gripper is ready for
production.
Extend the left cylinder down; loosen the clamp to adjust the cylinder to meet the template. Tighten the clamp once in correct position. Remove the template, so robot gripper is ready for production.